Service 04 · Embedded & real time

When the millisecond matters, off-the-shelf software no longer cuts it

C/C++ firmware optimised for your microcontrollers and boards: controlled latency, small memory footprint, deterministic behaviour.
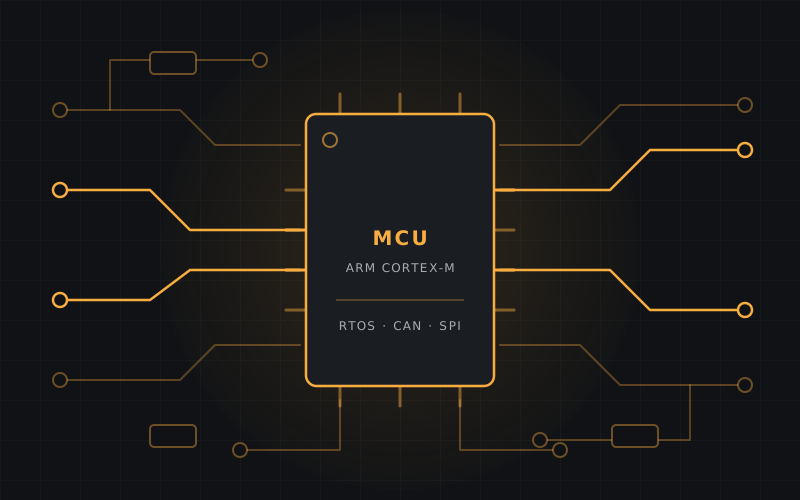
Embedded circuit board with ARM Cortex-M microcontroller, printed circuit traces and CAN, SPI buses

The service at a glance

Unlock the potential of your embedded hardware

We write software optimised for low latency, minimal memory footprint and maximum reliability. Our embedded solutions are aimed at industrial equipment where performance and determinism are non-negotiable.

The goal: predictable performance, lower hardware cost and a longer service life for systems built to last.

Key features

  • Language expertise — development in C and C++ for resource-constrained environments.
  • Real-time capabilities — support for the FreeRTOS and Zephyr RTOS and for bare-metal programming.
  • Protocol support — integration of CAN, Modbus, SPI, I2C and specific industrial buses.
  • Hardware compatibility — STM32, i.MX6, ESP32 microcontrollers, Raspberry Pi boards and bespoke boards.
  • Remote updates — OTA with secure bootloader, dual bank and automatic rollback.

Use cases

Where our firmware runs today

PLC and controller firmware

Software layer of industrial control boards, from boot-up to bus communication.

Robotic control systems

Motion planning and sensor fusion with low-latency control loops.

Edge computing

Local processing of IoT data so that only useful information reaches the network.

Safety applications

Emergency stop systems and critical functions with deterministic behaviour.

The expected outcome

Deterministic performance and hardware that lasts

Well-written firmware often makes it possible to stay on a cheaper microcontroller, avoid a hardware redesign and extend the life of an equipment range by several years.
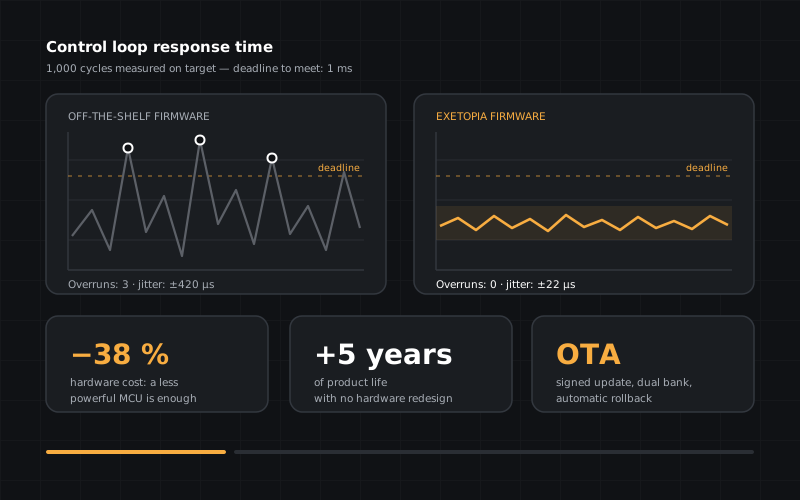
  • Lower hardware cost — software optimisation avoids over-specifying the target.
  • Predictable behaviour — response times bounded and measured, not estimated.
  • Longevity — code documented, tested and maintainable across the whole product life cycle.
Response time comparison: erratic off-the-shelf firmware against EXETOPIA firmware with controlled jitter

Technical specifications

Hardware targets, real-time systems and buses

Development

  • C, C++ — bare metal and RTOS
  • Assembly for performance-critical sections

Quality

  • Unit tests on target and on host
  • Static analysis and coverage measurement
  • Continuous integration with cross-compilation

Frequently asked questions

Questions about embedded systems

Yes. We start from your schematic and bill of materials to develop or take over the firmware. If the board is still to be designed, we advise on the microcontroller choice and review the schematic from a software standpoint before routing.

Bare metal suits simple firmware, with a single control loop and a minimal memory footprint. An RTOS becomes necessary as soon as several concurrent tasks have to meet distinct deadlines — communication, acquisition and control in parallel. We decide during scoping, backed by CPU load figures.

Yes. We implement Over-The-Air updates with a secure bootloader, dual memory banks to allow automatic rollback on failure, and cryptographic signing of the firmware to prevent any unauthorised image from being installed.

Going further

The other building blocks of your software chain

HMI & supervision

Operator interfaces, SCADA and touch panels connected to your PLCs.

See the service

Desktop applications

Machine configuration, simulation, diagnostics and quality analysis on your workstations.

See the service

Mobile applications

Work orders, field readings, code scanning and machine alerts for your technicians.

See the service

Firmware to write, take over or optimise?

Tell us the hardware target and the real-time constraint to meet: we come back to you within 24 working hours with a first feasibility analysis.